Back close

Soil-Sampling Robot

Dept/Center/Lab: AMMACHI Labs- Amrita Multi Modal Applications Using Computer & Human Interaction

Project Incharge:Dr. Bhavani Rao R.
Co-Project Incharge:Vishnu Rajendran
Funded by:Amrita Vishwa Vidyapeetham
Soil-Sampling Robot

Project Summary:

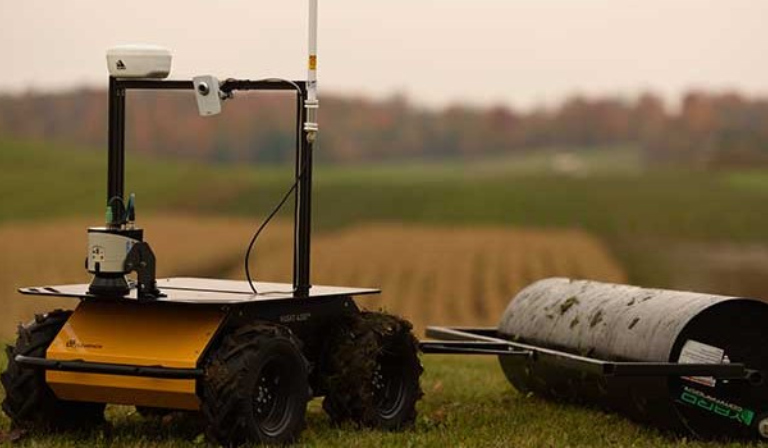
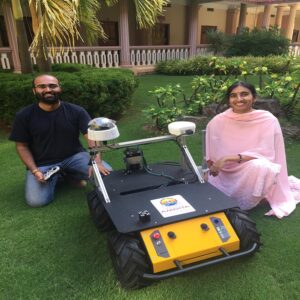
In post-disaster scenarios, especially those dealing with soil contamination by hazardous materials, it is important that soil quality be measured without putting human lives at risk. Our engineers designed and implemented an autonomous soil sampling solution based on the platform for monitoring the presence of heavy metals in landfills. The design consists of a soil sampling mechanism mounted on a Husky which auto-navigates through landfills and reaches the identified locations for soil sampling. The robot has a specially designed auger for collected the soil top layer from the landfill. A hybrid SLAM algorithm was also developed for navigating the robot.

Project Status:

Completed Project (December 12, 2019 – December 12, 2019)

Project Tags:

Rural Technologies

Related Projects

SDR based Modem for Spacecraft Telemetry reception, Telecommanding and Ranging Operations
A Human-Centered AI Framework for Multilingual Rural Field Reporting, Qualitative Insight, and Community Support
Adaptive and automatic insulin pump
Morbidity Management and Rehabilitation of Lymphatic Filariasis patients in Cherthala
Development of a method to Control Ultraviolet Radiation in welding Processes
Admissions Apply Now